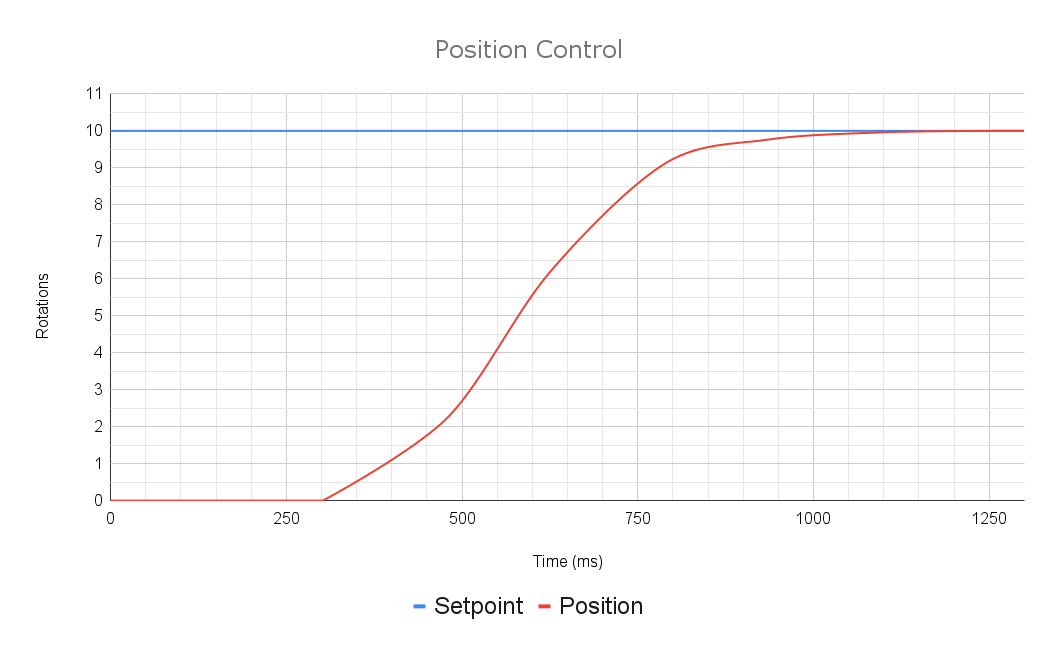
Position Control is used to point the motor in a specific direction. It takes a setpoint in rotations (or whatever unit your selected encoder's position conversion factor is in) and uses the PID loop to move to that position. The Position control mode pipes directly into a PID controller with the configured encoder.
A properly tuned Position control loop should respond quickly and accurately to a setpoint change and should not oscillate around the target.
To run the motor in Position control mode, set the PID Controller setpoint as shown below.
API Docs:
API Reference:
m_controller.setSetpoint(setPoint, ControlType.kPosition);using namespace rev::spark;
m_controller.SetSetpoint(setPoint, SparkBase::ControlType::kPosition);