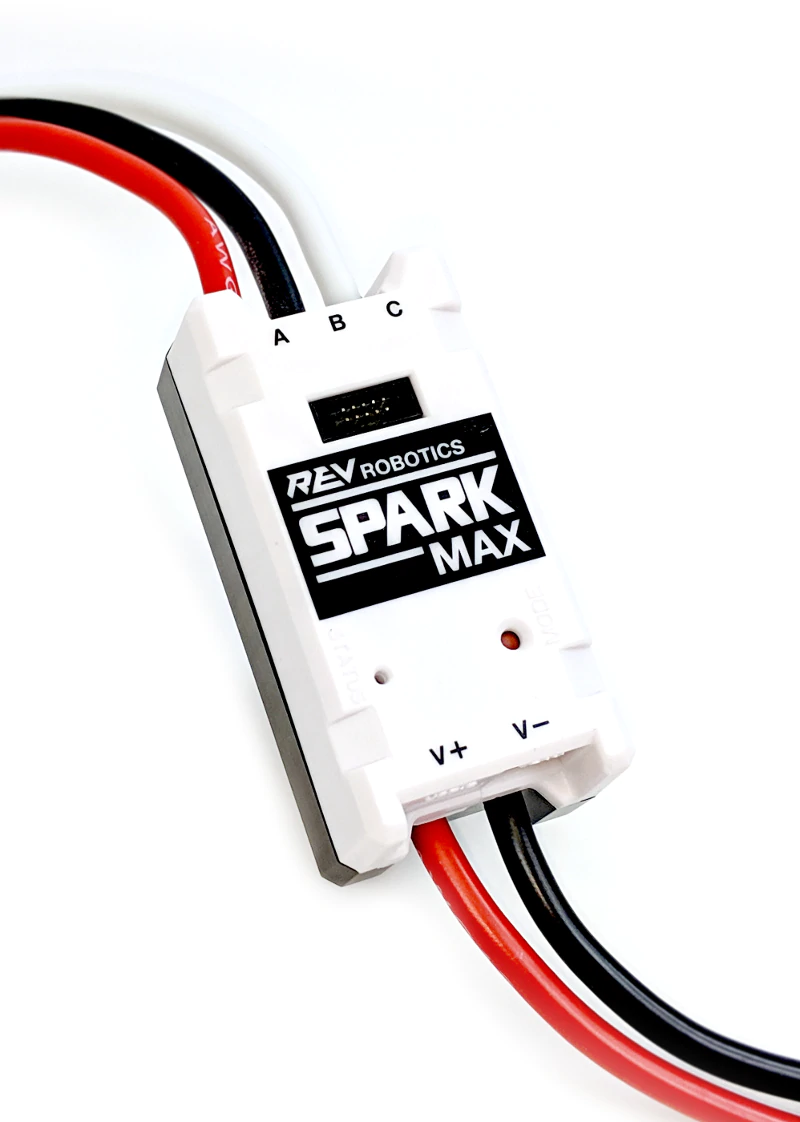
The REV Robotics SPARK MAX Motor Controller (REV-11-2158) is an all-in-one USB, CAN, and PWM enabled motor controller that can drive both 12 V brushed and 12 V brushless DC motors. SPARK MAX is designed for use in the FIRST Robotics Competition (FRC), incorporating advanced motor control in a small, easy-to-use, and affordable package. Configure and run the SPARK MAX through its built-in USB interface without needing a full control system.
Brushed and sensored-brushless motor control
PWM, CAN, and USB control interfaces
PWM/CAN - Locking and keyed 4-pin JST-PH
USB - USB type C
USB configuration and control
Rapid configuration with a PC
Smart control modes
Closed-loop velocity control
Closed-loop position control
Follower mode
Encoder port
Locking and keyed 6-pin JST-PH
3-phase hall-sensor encoder input
Motor temperature sensor input
Data port
Limit switch input
Quadrature encoder input with index
Multi-function pin
Mode button
On-board motor type and idle behavior configuration
RGB status LED
Detailed mode and operation feedback
Integrated power and motor wires
12 AWG ultra-flexible silicone wire
Passive cooling
The following items are included with each SPARK MAX Motor Controller
1 - SPARK MAX Motor Controller
1 - USB-A male to USB-C cable
1 - 4-pin JST-PH to CAN cable
1 - 4-pin JST-PH to single PWM cable
We appreciate the assistance from the community for feedback, contributions, and testing the SPARK MAX, especially .
1 - PWM/CAN cable retention clip
1 - Data port protection cap